Design and Integration of a Compact Mobile Outdoor Soil Sampling Agricultural Robot
Objective
To design and integrate a mobile agricultural robot for automated soil sampling. The system aims to improve soil data collection efficiency in farming environments.
Abstract
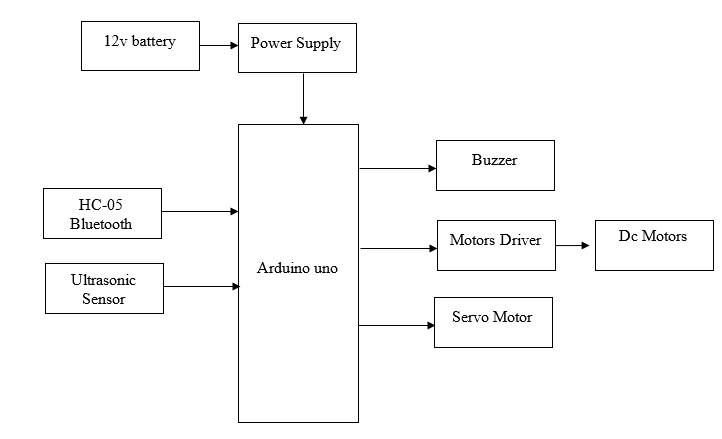
Soil sampling is a fundamental step in agricultural analysis, helping farmers and researchers assess nutrient levels, moisture content, and soil health across a field. Traditional soil sampling is carried out manually, which is slow, physically demanding, and prone to inconsistent results. This project presents a compact mobile outdoor agricultural robot designed to automate soil sample collection while navigating a field. The robot is built on a wheeled chassis driven by two DC motors through a motor driver, all controlled by an Arduino Uno. Movement is commanded wirelessly through a Bluetooth module, allowing an operator to remotely drive the robot across uneven outdoor terrain. An ultrasonic sensor mounted on the robot continuously scans for obstacles in its path; when an object is detected within a set threshold distance, the robot automatically halts to avoid collision. Once positioned at a desired location, a high-torque servo motor is actuated to collect the soil sample. Powered by a 12V battery through a regulated power supply, the system integrates mobility, obstacle safety, and sample collection into a single compact platform suitable for outdoor agricultural use.
NOTE: Without the concern of our team, please don't submit to the college. This Abstract varies based on student requirements.
Block Diagram
Specifications
Hardware components:
- Robot Chassis
- Arduino Uno
- Wheels-4
- Shaft-2
- Motors Driver
- Dc Motors
- Servo Motor
- Bluetooth
- 12v Battery
- Ultrasonic
- Power Supply
- Buzzer
Software requirements:
- Arduino-IDE
- Embedded-C
Learning Outcomes
- Arduino pin diagram and architecture
- How to install Arduino IDE / setup software
- Setting up and installation procedure for Arduino
- Introduction to Arduino IDE / development environment
- Basic programming in Arduino (Embedded C / C / C++)
- Basics of Embedded C / Arduino programming
- Basics of IoT platforms
- Working of power supply
- About Project Development Life Cycle:
- Planning and Requirement Gathering (software, tools, hardware components, etc.)
- Schematic preparation
- Code development and debugging
- Hardware development and debugging
- Development of the project and output testing
- Practical exposure to:
- Hardware and software tools
- Solution providing for real-time problems
- Working with team/individual
- Work on creative ideas
- Skills developed:
- Project development skills
- Problem analyzing skills
- Problem solving skills
- Creativity and imaginative skills
- Programming skills
- Deployment
- Testing skills
- Debugging skills
- Project presentation skills
- Thesis writing skills


 Paper Publishing
Request Call Back
Would you like to receive a free callback now?
Choose the best time for callback:
Leave your message and we will contact you as soon as possible
6-2-85/B, Old Maternity Hospital Road, Thyagaraja Nagar, Tirupati, Andhra Pradesh – 517501
+91 9030333433
+91 9393939065
0877-2261612

Disclaimer - Takeoff Edu Group Projects are not associated or affiliated with IEEE in any way. The IEEE Projects mentioned here are mentioned in the context of student projects, whose ideas are derived from IEEE publications, not projects of or by IEEE.